Meet our 1st Annual Canada Innovation Day Presenters
Toronto, Canada
November 17, 2026
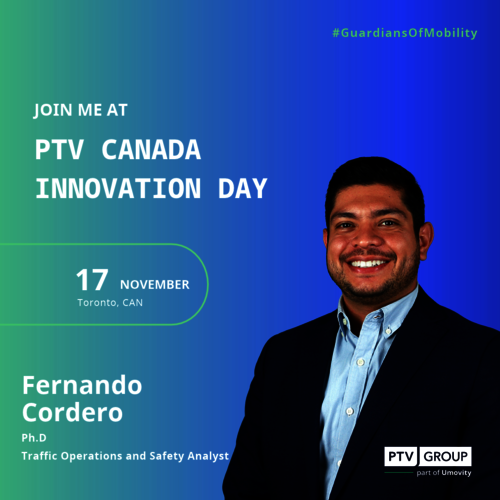
Fernando Cordero
Arcadis
Traffic Modeling for Corridor Planning Decisions: SR 316 Planning Study | Georgia, USA
This presentation uses the SR 316 Planning Study in Georgia, USA, as a case study to demonstrate how PTV Visum can integrate corridor-wide travel demand analysis with intersection-level operational assessment. The session explores model development, calibration, validation, and scenario testing, showing how the results were used to evaluate improvement alternatives and support planning decisions. Lessons learned from the study and their potential application to corridor planning projects in Canada will also be discussed.
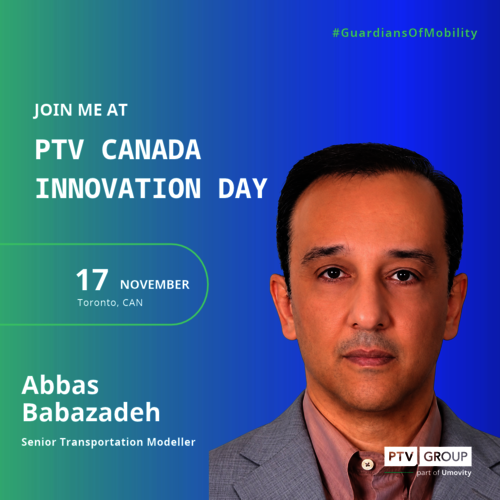
Abbas Babazedeh
AECOM Canada
TAZ Splitting with PTV Visum: A Maximum-Entropy Approach for Intrazonal OD Disaggregation
This presentation examines a practical extension to the standard TAZ-splitting workflow in PTV Visum for redistributing parent-zone intrazonal demand. Using a maximum-entropy framework and a calibrated within-parent association term, the approach preserves the required production and attraction totals while improving the representation of localized OD movements. The method is demonstrated and evaluated using PTV Visum through OD reconstruction and traffic-assignment comparisons.
Jowel Akkeh
York University
Policy Driven Level of Service for Mixed Pedestrian-Robot Environments: A PTV VISWALK Application
This project uses PTV Viswalk microsimulation to model interactions between pedestrians and Sidewalk Autonomous Delivery Robots (SADRs) in shared sidewalk environments. The model combines pedestrian behavior, robot movement, Social Force Model parameters, and customized Viswalk attribute modifications to simulate yielding, avoidance, and pedestrian-robot interactions under different operating conditions. Simulation results are used to develop a policy-sensitive Pedestrian-Robot Level of Service (PRLOS) framework that evaluates how factors such as robot speed, fleet density, yielding rules, and pedestrian density affect sidewalk performance. The research demonstrates how PTV Viswalk can be extended to model pedestrian-robot environments and support evidence-based transportation planning and policy
Matheus Never
TYLin
Crowd Management Study – Maid of the Mist
This presentation explores how microsimulation was used to evaluate pedestrian flow and crowd management at the Maid of the Mist attraction in Niagara Falls, USA. The study evaluated existing conditions and different scenarios, including the impact of the proposed Crow’s Nest staircase extension in combination with different elevator operating strategies under peak visitor demand. The results demonstrate how microsimulation can be used not only to assess pedestrian infrastructure, but also to test different scenarios and optimize real-world operational strategies for managing crowds at high-volume tourist attractions.
Kritika Saini
AECOM
Crash Analysis Tool (CAT): A Trajectory-Based Quality Assurance Tool for VISSIM
VISSIM models are widely used to support transportation operational assessments and design decisions, making model quality essential to producing reliable results. Vehicle overlapping is one modeling issue that can significantly affect model quality; however, manually reviewing large microsimulation models to identify these events can be a tedious and time-consuming process.
This presentation introduces the Crash Analysis Tool (CAT), an automated application developed to detect vehicle overlap events from VISSIM trajectory outputs and identify the location and timestamp of each event within the model. The presentation will demonstrate how CAT streamlines model quality assurance, reduces manual review effort, and helps improve the accuracy and reliability of microsimulation results.
Dorsa Moghaddaszadeh
York University